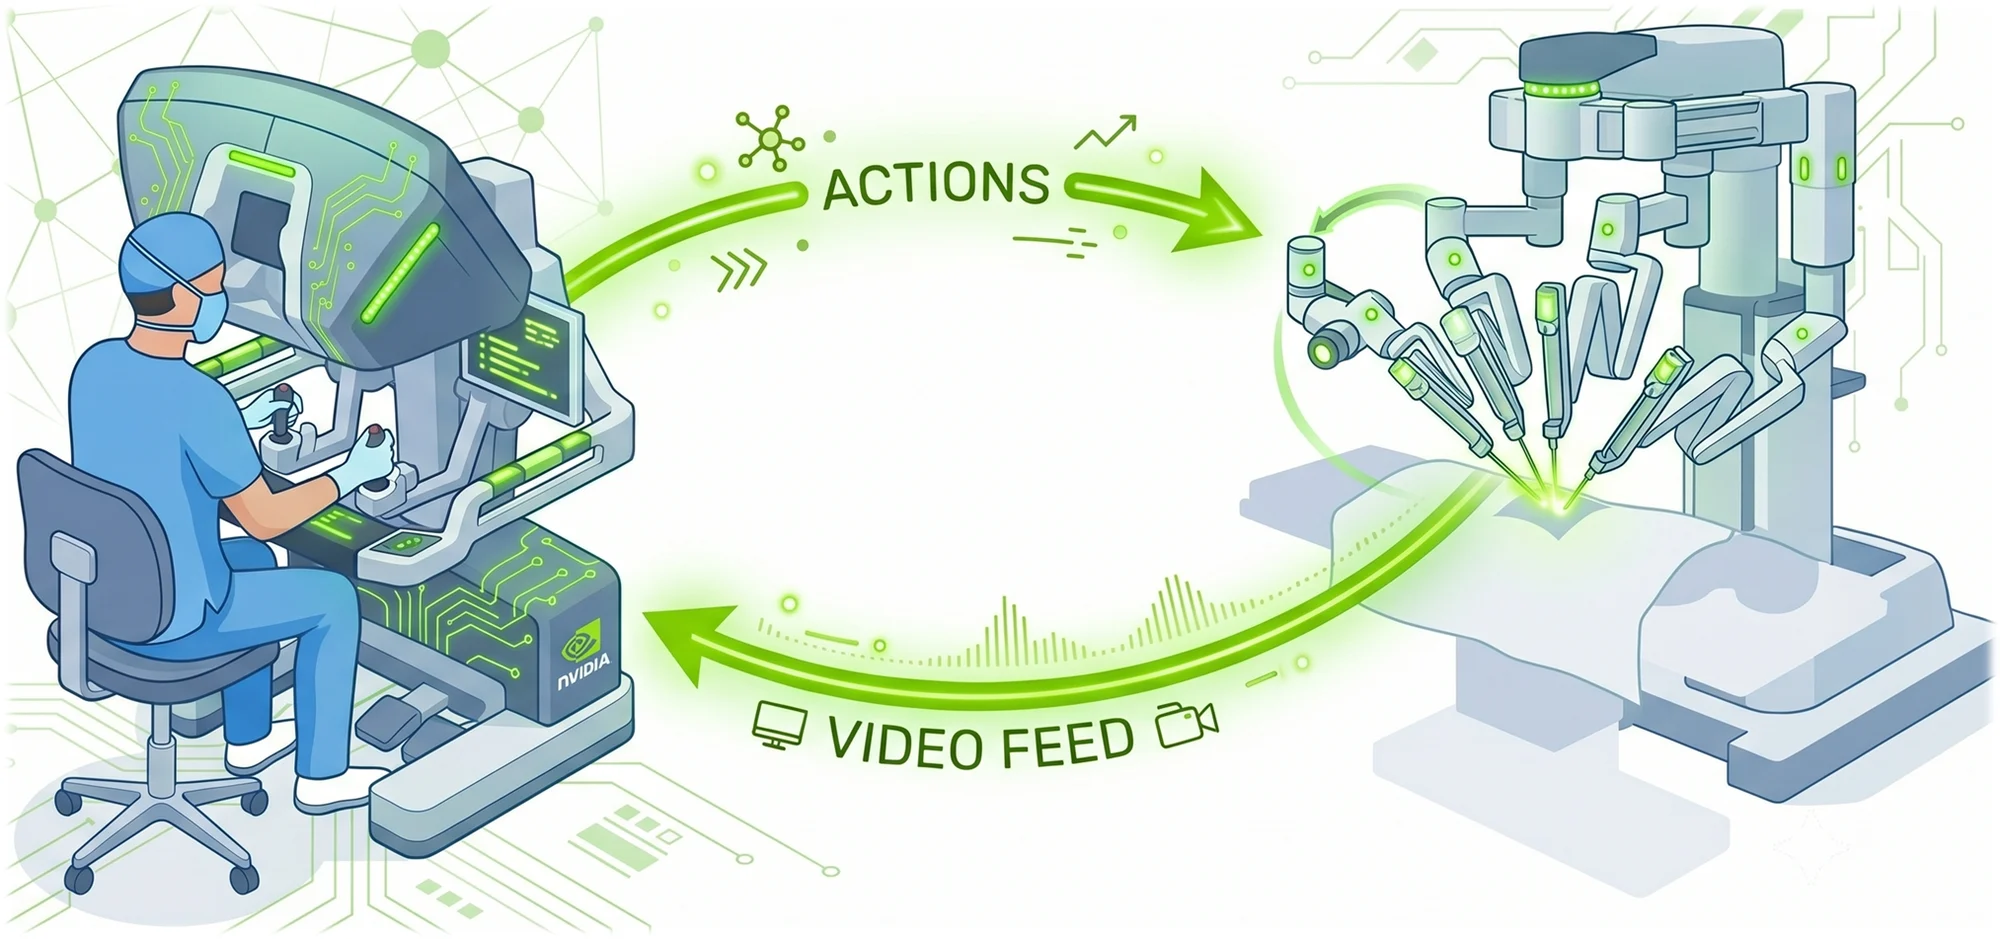
Az NVIDIA kiadta a Cosmos3-H-Dreams elnevezésű generatív világmodelljét, amely klinikai műtétek valós idejű, interaktív szimulációjára képes. A rendszer nem fizikai modellezést használ, hanem a videókból és a robot kinematikai adataiból tanulja meg a szövetek deformációját és a műszerek mozgását.
A CMR Surgical Versius platform epehólyag-eltávolítási felvételein betanított modell FlashDreams gyorsítókönyvtárral fut, így egyetlen NVIDIA RTX PRO 6000 GPU-n is képes valós időben reagálni az irányításra. A fejlesztők 4 lépéses és 2 lépéses verziót is elérhetővé tettek a vizuális minőség és a generálási sebőség egyensúlyozásához.
A nyílt forráskódú recept segítségével a kutatók saját videóikra és robotrendszereikre is adaptálhatják a modellt. A Cosmos3-H-Dreams egyelőre kutatási eszköz, nem klinikailag validált orvosi rendszer.
Az eredeti szöveg (Hugging Face)
1. From Tabletop Tasks to Clinical Scenes 2. What is New in Cosmos3-H-Dreams? 2.1 A Cosmos 3 Foundation and Richer Surgical Controls 2.2 From Teacher to Four-Step and Two-Step Students 2.3 Streaming through FlashDreams 3. Exploring Unseen Trajectories 4. Adapting to Your Own Data and Controller 5. What is Next 6. Get Started Today Picture moving the Cadiere grasper, grasping the gallbladder, and lifting it, all within a generated surgical scene that responds in real time. Today, we take the next step and introduce Cosmos3-H-Dreams, bringing interactive generative simulation to the visual and procedural complexity of clinical surgery with our most convincing in-body imagery to date.
Our first Cosmos-H-Dreams release, built on Cosmos-Predict2.5, brought interactive generative simulation to dVRK tabletop suturing, a foundational proving ground for surgical robotics. As world foundation model (WFM), Cosmos-H-Dreams demonstrated an alternative to numerical simulation: rather than explicitly modeling scene geometry, tissue deformation, and physical interactions, it learned visual dynamics directly from synchronized video and robot kinematics, yielding interactive tabletop task simulation with high realism.
Today, Cosmos3-H-Dreams advances this capability by learning from video and robot kinematics recording during clinical procedures on the CMR Surgical Versius platform. To our knowledge, this is the first real-time generative surgical simulator trained on clinical cholecystectomy recordings to support live kinematic control. Powered by Cosmos 3 and accelerated with FlashDreams, NVIDIA’s accelerated streaming-inference library, Cosmos3-H-Dreams runs interactively on a single NVIDIA RTX PRO 6000 GPU.
In a controlled tabletop environment like that of Cosmos-H-Dreams, instruments operate against a relatively simple background. Inside the human body, however, small instrument movements can affect an entire scene: tissue stretches under traction, reflections shift, structures become occluded, and smoke changes visibility. Given an initial image and supplied tool actions, a generative simulator must capture these responses while preserving the anatomy and instruments as it generates each new block of video. Small errors can accumulate over time, gradually changing instrument geometry or anatomical structure, making temporal consistency essential.
Visual realism is therefore a starting point for validation, not proof of biomechanical accuracy. The generated scene must also follow the controls: translation, rotation, and gripper commands should produce coherent anatomical consequences. A plausible-looking rollout that ignores those commands cannot serve as an interactive environment.
Maintaining this fidelity and responsiveness in a live control loop requires low latency generation. Cosmos3-H-Dreams addresses this setting through a model specialized for clinical cholecystectomy and distilled for real-time generation, bringing action-conditioned interaction into scenes with complex anatomy, tissue motion, and occlusion.
Cosmos3-H-Dreams builds on Cosmos3-H-Embodied-Nano, a 16-billion-parameter model pretrained on Open-H-Embodiment, and specializes a bidirectional teacher on curated cholecystectomy video and kinematics. Sample selection targets two visible, engaged instruments, a left Cadiere grasper and a right monopolar hook, and limits camera commands to emphasize instrument-driven interaction.
The model uses 28 action dimensions: pose and gripper information for both arms, plus energy controls, thumbstick axes and thumbstick buttons. Training uses 832 x 480 video with actions aligned at 10 Hz; that sampling rate is distinct from runtime generation throughput.
Cosmos3-H-Dreams combines a teacher-to-student training pipeline designed for long autoregressive rollouts with accelerated streaming inference through FlashDreams.
We first adapt the bidirectional teacher on 24 future frames, then extend the horizon to 72 frames, 2.4 and 7.